
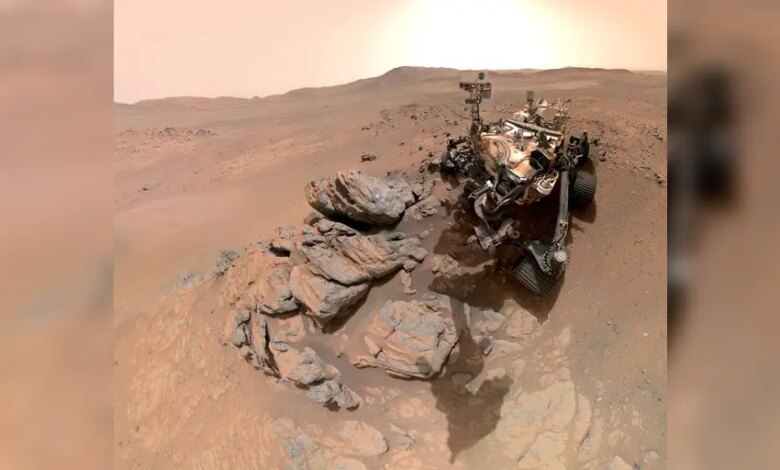
NASA’s Perseverance Mars rover has set a new world record for the farthest distance driven by any vehicle on the surface of another world. On October 11, the robotic explorer reached a cumulative total of 28.10 miles, eclipsing the previous mark of 28.06 miles set by its predecessor, the Opportunity rover.
The milestone coincides with three decades of continuous NASA rover operations on the Martian surface. The achievement also far exceeds the initial projections laid out during mission planning, which anticipated no more than 12.4 miles of total driving.
Steven Lee, project manager for the Curiosity and Perseverance rovers at NASA’s Jet Propulsion Laboratory in Southern California, noted that the vehicle has surpassed expectations. With all mobility systems fully operational and favorable extended-ground-life test results, engineers expect Perseverance to continue adding to the record.
The record-breaking drive occurred as Perseverance navigated toward an area known as “Idubi,” situated off the western rim of Jezero Crater. Mission scientists are investigating the region as a potential site of some of the oldest terrain ever explored in the solar system, with the primary scientific goal of uncovering traces of ancient hydrothermal systems.
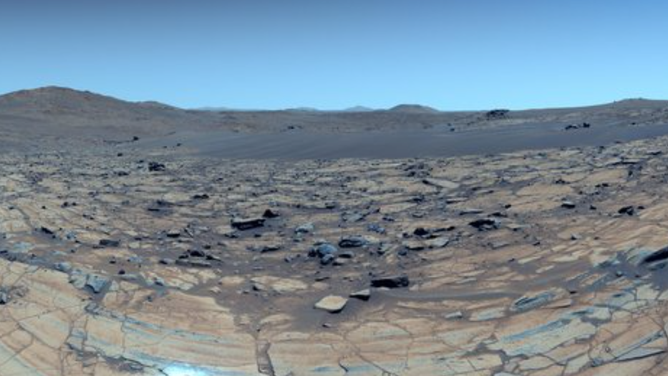
A significant factor in the rover’s mobility success is its autonomous navigation system, known as AutoNav. The software allows the vehicle to capture terrain images while in motion, construct a three-dimensional map of potential hazards, and calculate a safe course between waypoints designated by operators on Earth.
Perseverance has relied heavily on this capability, covering more than 90 percent of its total driving distance using AutoNav. By comparison, the earliest version of the autonomous driving system on the Opportunity rover was utilized for roughly 5 percent of its total journey.
Mark Maimone, deputy team chief for robotic operations on Perseverance, explained that recent software updates have enhanced the rover’s efficiency. The system enables the vehicle to steer less and roll more frequently, while periodically verifying its position against orbital maps mid-drive.
Looking ahead, mission engineers are targeting environmental challenges to further extend operational efficiency. Sunlight glare in the navigation cameras currently requires operators to park the rover by mid-afternoon if it is traveling toward the sun. Developing software that allows the vehicle to navigate past these optical artifacts remains a key frontier, potentially allowing future rovers extended working hours on the Martian surface.


